Mechanics, electrical, software and vision all sit in one team — one less subcontractor means one less unclear line of responsibility.
Custom equipment rarely fails because one discipline is weak; it fails because the disciplines do not connect. Our answer is to own all of them.
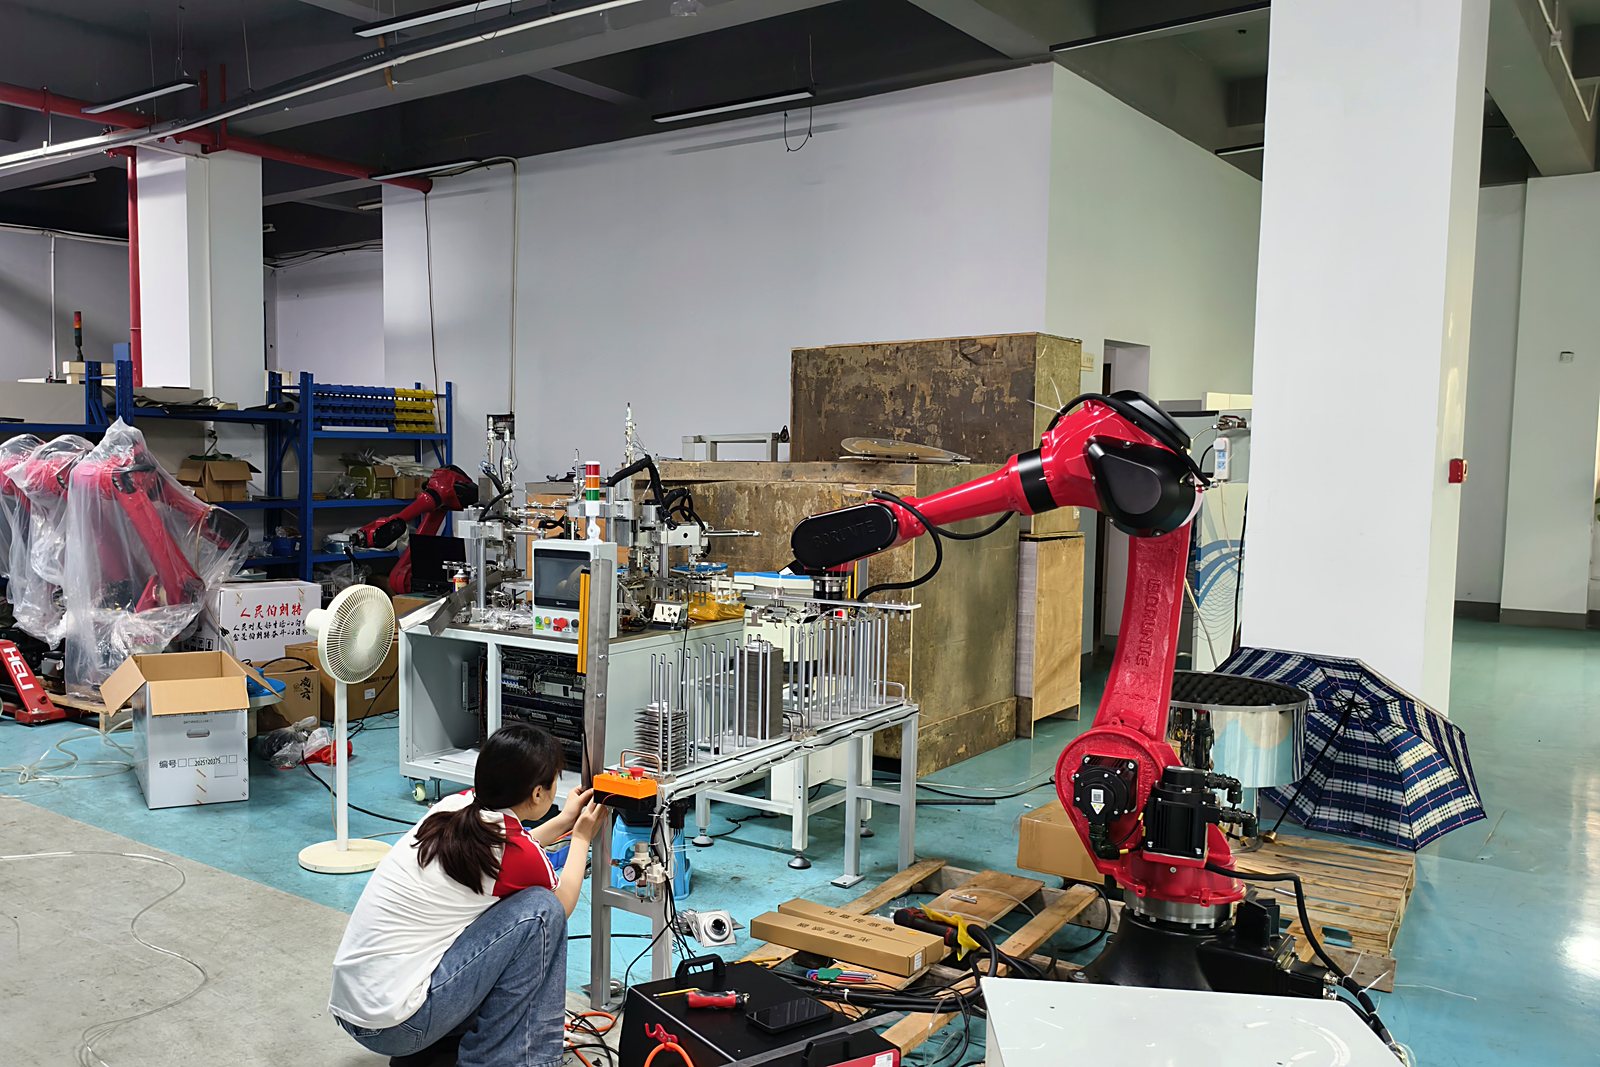
Robot selection and modification, end effector design, cycle-time simulation and path planning.
Guidance, dimensional measurement and surface defect inspection, with algorithms and lighting designed as one.
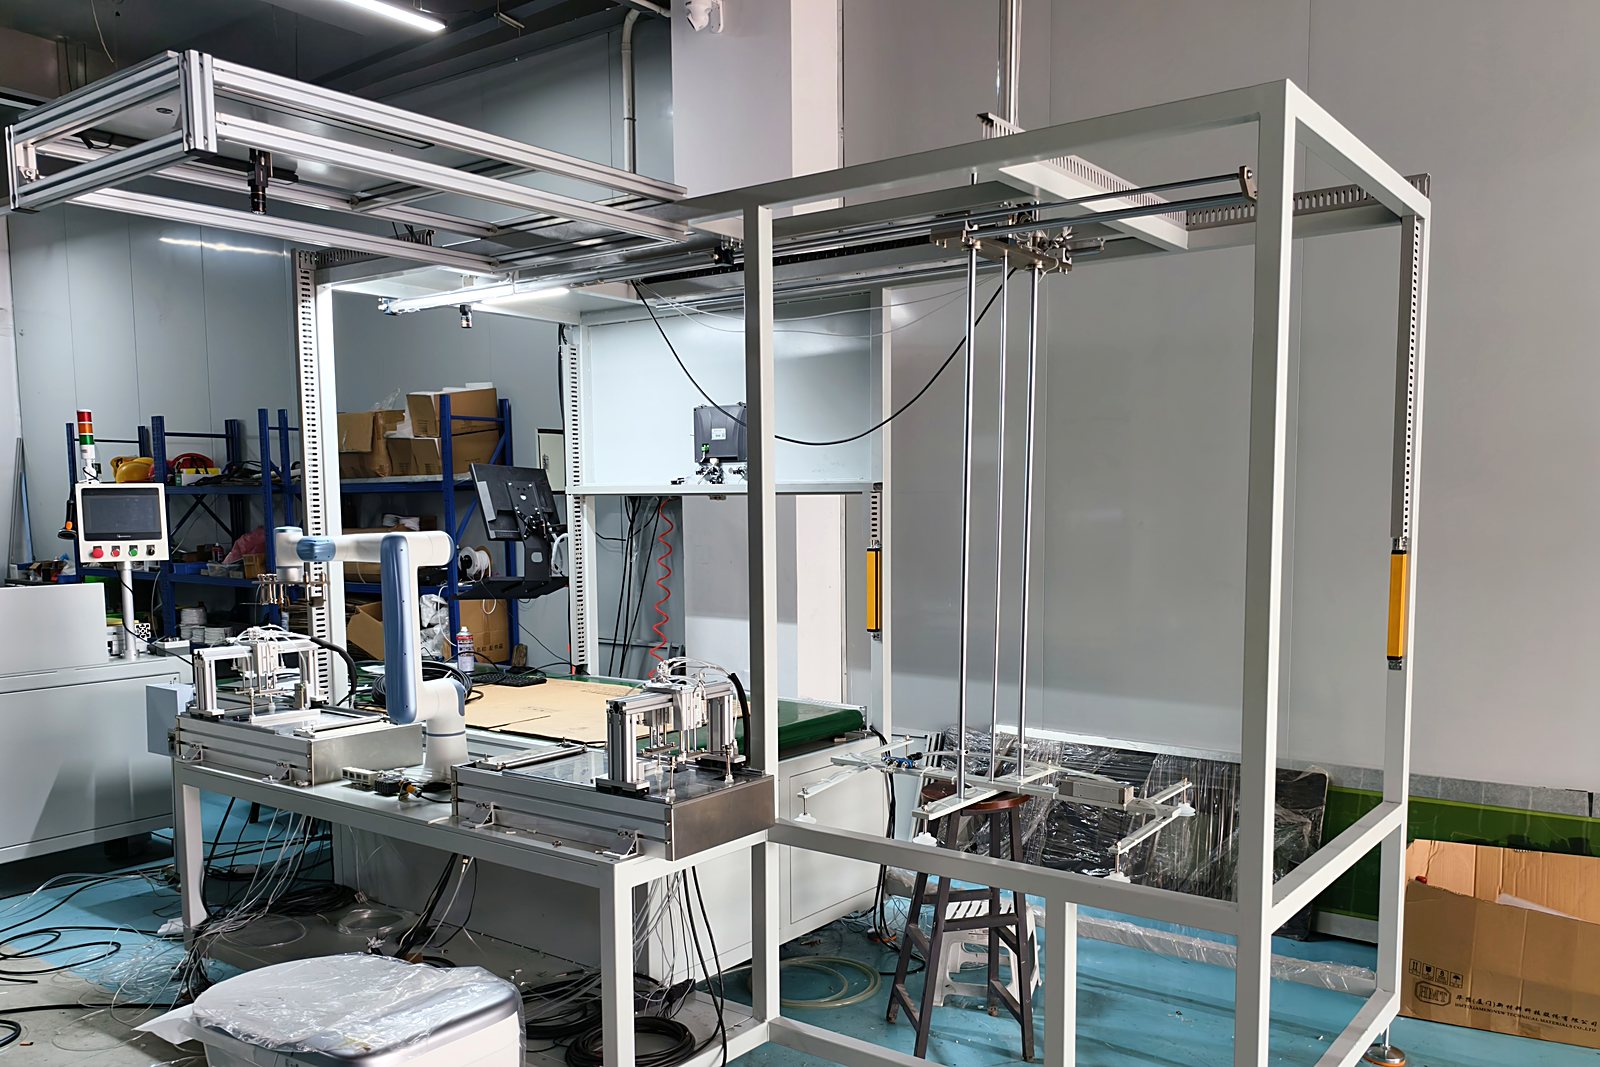
Machine structure, feeding and separating, transport and positioning, line interlocking and in-house commissioning.
PLC programs, HMI, recipe management, data interfaces and platform connectivity.
A robot does not work just because you bought and installed it. Selection, end effector, path, cycle time and handover to the neighbouring process each decide whether it works or just stands there.
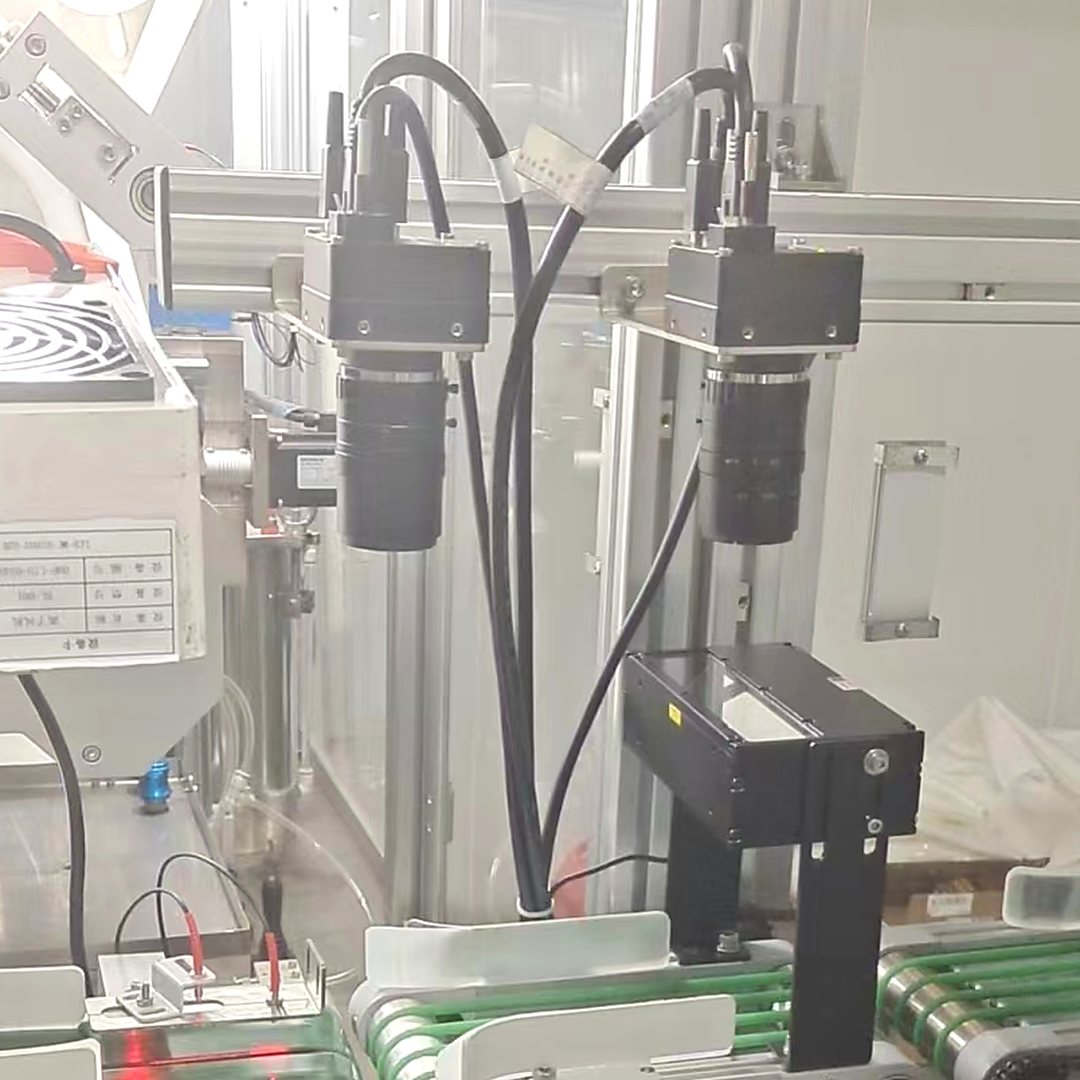
The hard part of vision is usually not the algorithm but the image itself. Poor lighting defeats the best model. We always design the lighting and the algorithm together.
Between the concept and the delivered machine lies a great deal of structural detail. We treat that detail as product work, not as drawing work.
Coordination between machines and the flow of data end up in software. We do not build islands of equipment.
Every step from requirement to maintenance has someone inside the team who owns it.
| Stage | Capabilities | Deliverables |
|---|---|---|
| Requirement and concept | Site survey, process breakdown, cycle-time measurement, return-on-investment assessment | Requirement document, process concept, layout drawing |
| Mechanical design | Machine structure, transport mechanisms, fixtures, feeding and separating mechanisms | 3D models, assembly drawings, part drawings |
| Robot and end effector | Selection and modification, end effectors, path and cycle-time simulation | Selection report, end effector drawings, simulation results |
| Vision system | Camera and lens selection, lighting concept, algorithm development and tuning | Imaging concept, algorithm programs, acceptance criteria |
| Electrical and software | Schematic design, PLC programs, HMI, data interfaces | Electrical drawings, program backups, communication protocols |
| Manufacturing and commissioning | In-house machining, final assembly, in-house testing and interlock commissioning | Complete machine, test report (FAT) |
| Delivery and support | On-site installation and commissioning, training, spare parts, technical support | Operation manual, spare parts list, acceptance report (SAT) |
The biggest risk in a custom project is building the wrong thing. We break the process into steps so you can accept, stop or adjust at each one.
We go on site, watch the process, measure cycle times and map out yield bottlenecks and expansion plans.
A process concept and layout drawing, with cycle time, manning and return on investment made explicit.
Mechanical, electrical and vision design in parallel, with critical components selected and frozen.
In-house machining and standard-part procurement run in parallel, with final assembly in our workshop.
We run the machine on the customer's real parts; once targets are met we invite them in for factory acceptance (FAT).
On-site installation and commissioning (SAT), training, and long-term support with spare parts.
Describe the process, the cycle time and how you do it today. We will give an honest judgement and no promises we cannot back up.
Tel +86 159 6080 5171 · Email soda@byrobot.com.cn